Complex Number to Polar Form Calculator (Modulus, Argument and Quadrant Steps with a Complex Plane Graph)
Choose the direction of the conversion and enter the numbers. For rectangular to polar, enter the real part a and the imaginary part b. For polar to rectangular, enter the absolute value r and the argument θ (and choose its unit).
Table of Contents
-
What you can do on this page
-
What is this calculation used for?
-
How to Use
-
Formulas and figures
-
Symbols and terms
-
Good to know before you start
-
How to calculate it in Excel
-
How to calculate it in Google Sheets
-
How to calculate it in Python
-
How to write it in LaTeX and other math languages (copy and paste)
-
How to have ChatGPT do the calculation
-
DataChef Features
-
Related Features
-
NumberChef Calculators List
What you can do on this page
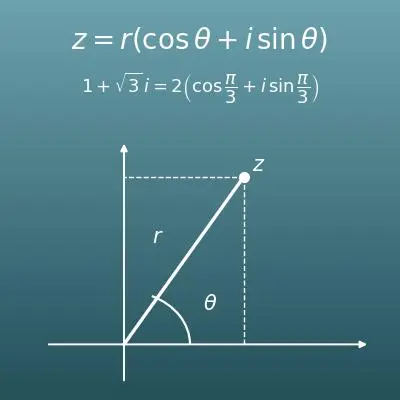
- Convert a complex number \(z = a + bi\) (rectangular form) on the spot to polar form \(r(\cos\theta + i\sin\theta)\), using the absolute value \(r\) and the argument \(\theta\). The absolute value is given as an exact value with the radical simplified, such as \(\sqrt{8} = 2\sqrt{2}\), and for special angles the argument is an exact fraction of π
- The argument \(\theta\) is given mainly in the range \(0 \le \theta < 2\pi\), with the value in the range \(-\pi < \theta \le \pi\) (the principal argument) shown as well, so you can check your answer whichever convention your textbook uses
- It also converts the other way (polar form to rectangular form). Enter the absolute value \(r\) and the argument \(\theta\) (in degrees, as a fraction of π, or as a decimal in radians), and \(a + bi\) is shown as an exact value such as \(1 + \sqrt{3}i\)
- The steps show, one at a time, how the argument is found from \(\tan\theta = \dfrac{b}{a}\) and the quadrant the point is in (the quadrant adjustment)
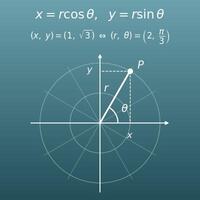
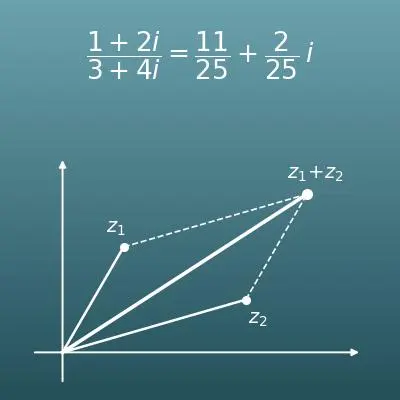
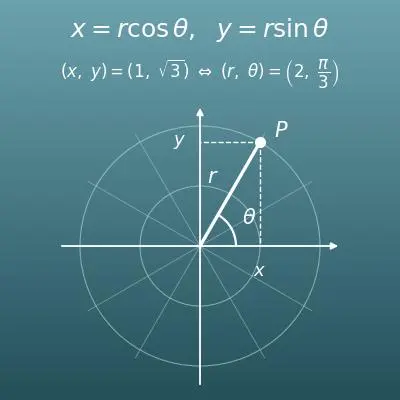
- You can also see the result on the complex plane, which shows at a glance where the absolute value \(r\) (the distance from the origin) and the argument \(\theta\) (the angle of rotation from the real axis) are
What is this calculation used for?
The alternating current (AC) in a wall outlet has a voltage and current that swing like waves, carrying two pieces of information: the size of the wave and the shift in its timing (the phase). In electrical engineering, both are held in one complex number (absolute value = size of the wave, argument = phase), and the standard method is to multiply and divide in polar form to solve the circuit. Engineers call this phasor notation.
The design of the power grid from the power plant to your home, and of the circuit inside a phone charger, relies on these "absolute value and argument" calculations. It is the most common everyday use of complex numbers in engineering work, and it appears on engineering licensing exams such as the FE and PE exams.
When a computer handles sound or radio waves, it breaks them down with a calculation called the Fourier transform into "how much of each wave pitch is in it". The result is a list of complex numbers: the absolute value of each one is the strength of that wave (the amplitude), and the argument is its shift (the phase).
Many technologies that handle sound and radio waves, such as equalizers in music apps, noise canceling in earbuds and speech recognition, are built on this idea of reading a complex number by its absolute value and argument.
The polar form rule "multiply the absolute values, add the arguments" is, geometrically, just "scaling and rotating". For example, multiplying by \(i\) (absolute value 1, argument 90°) rotates a point exactly 90° around the origin. In 2D games, the math for turning a character or a bullet can be written as complex multiplication.
Quaternions, used in 3D graphics and robot control, extend this idea of "rotation by complex numbers" to three dimensions.
Airport radar and ship sonar locate a target by a pair: "how far away it is" and "in which direction". This is the same idea as polar form (polar coordinates), which describes a point by \(r\) and \(\theta\). The same kind of conversion as on this page is done to turn it into the position shown on the screen (horizontal and vertical coordinates).
Whenever "distance and direction" is the natural way to describe a position, this conversion to and from rectangular coordinates shows up.
Formulas and figures
Symbols and terms
Symbols
| \(i\) | i | The imaginary unit, the number whose square is \(-1\) (\(i^2 = -1\)). The letter comes from "imaginary". |
| \(z\) | z | The letter usually used for a complex number. By custom, \(z\) and \(w\) are used for complex numbers, to tell them apart from real variables \(x,\ y\). |
| \(a,\ b\) | a, b | The real part (\(a\)) and the imaginary part (\(b\)) of \(z = a + bi\). Both are real numbers. On the complex plane, \(a\) is the position across (along the real axis) and \(b\) is the position up (along the imaginary axis). |
| \(r\) | r | The letter for the absolute value (the distance from the origin to the point \(z\)). It comes from "radius". In polar form it is a real number that is 0 or more. |
| \(|z|\) | absolute value of z | The symbol for the absolute value (modulus) of \(z\). It is written with two vertical bars, the same as for a real number, and \(|a + bi| = \sqrt{a^2 + b^2}\). |
| \(\theta\) | theta | The Greek letter used for the argument. In math it is the usual letter for an angle. |
| \(\arg z\) | arg z | The symbol for the argument of \(z\), from the first three letters of "argument". It is used as in \(\arg z = \theta\). |
| \(\cos\theta,\ \sin\theta\) | cosine theta, sine theta | Trigonometric functions. On the circle of radius 1 (the unit circle), the point in the direction of angle \(\theta\) has horizontal position \(\cos\theta\) and vertical position \(\sin\theta\). In polar form they are the part that gives the direction. |
| \(\tan\theta\) | tangent theta | A trigonometric function defined by \(\tan\theta = \dfrac{\sin\theta}{\cos\theta}\). On the complex plane, \(\tan\theta = \dfrac{b}{a}\) (rise over run, the slope), which is the key to finding the argument. |
| \(\arctan\) | arctangent | The inverse of tangent (also written \(\tan^{-1}\)). It returns "the angle \(\theta\) with \(\tan\theta = x\)". The angle it returns is always between \(-\dfrac{\pi}{2}\) and \(\dfrac{\pi}{2}\), so the quadrant adjustment is needed for arguments in Quadrants 2 and 3. |
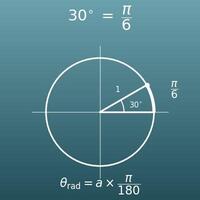
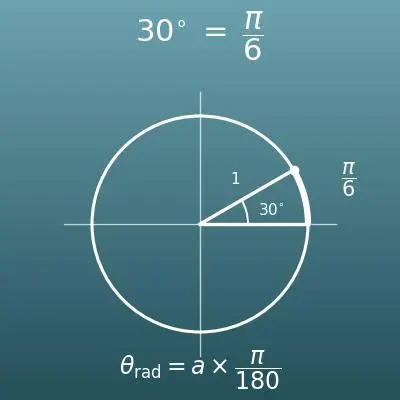
| \(\pi\) | pi | The ratio of a circle's circumference to its diameter (about 3.14159). In radians, a half turn, \(180^{\circ}\), is exactly \(\pi\). The Greek letter \(\pi\) is said to come from the first letter of the Greek word for "perimeter". |
Terms
| complex number | A number of the form \(a + bi\), where \(a\) and \(b\) are real numbers. It is a number system that brings the real and imaginary numbers together, taught in Algebra 2. |
| imaginary unit | The number \(i\) whose square is \(-1\). No real number has a negative square, so it was introduced as a new number. |
| real part | The \(a\) in the complex number \(z = a + bi\). On the complex plane, it is the horizontal coordinate. |
| imaginary part | The \(b\) in the complex number \(z = a + bi\). It is the real number in front of \(i\), without the \(i\) itself (the imaginary part of \(1 + 2i\) is \(2\), not \(2i\)). |
| complex plane | The plane where \(a + bi\) is shown as the point \((a,\ b)\). The horizontal axis is the real axis and the vertical axis is the imaginary axis. A drawing of it is also called an Argand diagram. It is taught in Precalculus. |
| rectangular form | Writing a complex number as \(a + bi\) (the coordinates \(a\) across and \(b\) up). Also called standard form. Addition and subtraction are easiest in this form. |
| polar form | Writing a complex number with its distance \(r\) from the origin and its angle of rotation \(\theta\) from the real axis, as \(r(\cos\theta + i\sin\theta)\). Also called trigonometric form. Multiplication, division and powers are easiest in this form. |
| absolute value (modulus) | The distance from the origin to the point \(z\), calculated as \(|z| = \sqrt{a^2 + b^2}\). It extends the absolute value of a real number (its distance from 0 on the number line) to the plane. |
| argument | The angle of the direction from the origin to the point \(z\), measured counterclockwise from the positive real axis. The symbol is \(\arg z\). Adding a full turn (\(2\pi\)) gives the same direction, so by convention the answer is given in a set range such as \(0 \le \theta < 2\pi\) or \(-\pi < \theta \le \pi\) (the principal argument). |
| quadrant | One of the four regions the two axes divide the coordinate plane into. The upper right is Quadrant 1 (often written I), and counting counterclockwise from there come Quadrants 2, 3 and 4. Which quadrant a point is in is the key to pinning down its argument. |
| radian measure (radians) | Measuring an angle by the length of the arc it cuts on a circle of radius 1. \(180^{\circ} = \pi\) radians. From trigonometric functions in Precalculus on, radians are the standard unit rather than degrees. |
| special angles | \(30^{\circ}\), \(45^{\circ}\), \(60^{\circ}\) and related angles (these plus multiples of \(90^{\circ}\)). Their trig values can be written exactly, as \(\dfrac{1}{2}\), \(\dfrac{\sqrt{2}}{2}\) and \(\dfrac{\sqrt{3}}{2}\), and most textbook and test problems use these angles. |
| quadrant adjustment | Within one full turn there are two angles with \(\tan\theta = \dfrac{b}{a}\), so you choose the one that matches the quadrant of the point (for example, by adding \(\pi\) to the acute angle from \(\arctan\)). |
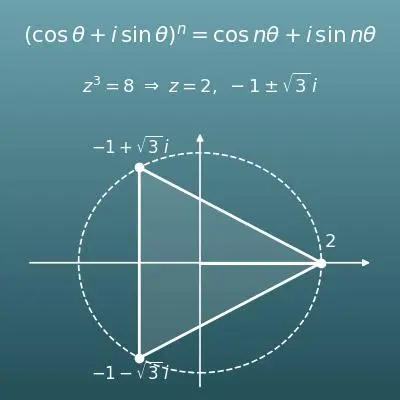
| De Moivre's theorem | The theorem \(\left(\cos\theta + i\sin\theta\right)^n = \cos n\theta + i\sin n\theta\). It is the result of repeating "multiplying adds the arguments" \(n\) times, and it is used to find \(n\)th powers and \(n\)th roots of complex numbers (Precalculus). |
Good to know before you start
Here is what helps you use the calculation on this page with real understanding, not just by pressing the button.
If you get stuck, going back over these topics is the quickest way forward.
| Square roots and radicals (Grades 8–9) |
|
| The Pythagorean theorem (Grade 8) |
|
| Complex numbers (Algebra 2) |
|
| Trigonometry and the unit circle (Geometry, Algebra 2) |
|
| Radian measure (Algebra 2, Precalculus) |
|
| The complex plane (Precalculus) |
|
How to calculate it in Excel
| Real part a | 3 |
| Imaginary part b | 4 |
| Absolute value r | =SQRT(B1^2+B2^2) |
| Argument θ (radians, 0 ≤ θ < 2π) | =MOD(ATAN2(B1,B2),2*PI()) |
| Argument θ (degrees) | =DEGREES(MOD(ATAN2(B1,B2),2*PI())) |
| Absolute value r | 2 |
| Argument θ (degrees) | 60 |
| Real part a = r cos θ | =B1*COS(RADIANS(B2)) |
| Imaginary part b = r sin θ | =B1*SIN(RADIANS(B2)) |
In the first table, ATAN2(x-coordinate, y-coordinate) returns the argument with the quadrant adjustment already done (greater than −π and up to π). Taking MOD with 2π turns it into an argument from 0 up to (but not including) 2π. For the example z = 3 + 4i, r = 5 and θ ≈ 0.9273 (about 53.13 degrees).
In the second table, RADIANS converts degrees to radians. For the example r = 2 and θ = 60 degrees, a = 1 and b ≈ 1.7320508 (= √3). Excel gives decimals, so if you want exact values such as √2 or fractions of π, use the calculator on this page.
How to calculate it in Google Sheets
| Real part a | 3 |
| Imaginary part b | 4 |
| Absolute value r | =SQRT(B1^2+B2^2) |
| Argument θ (radians, 0 ≤ θ < 2π) | =MOD(ATAN2(B1,B2),2*PI()) |
| Argument θ (degrees) | =DEGREES(MOD(ATAN2(B1,B2),2*PI())) |
| Absolute value r | 2 |
| Argument θ (degrees) | 60 |
| Real part a = r cos θ | =B1*COS(RADIANS(B2)) |
| Imaginary part b = r sin θ | =B1*SIN(RADIANS(B2)) |
How to calculate it in Python
import math

# Rectangular form -> polar form
real_part = 3        # real part a
imaginary_part = 4   # imaginary part b
absolute_value = math.sqrt(real_part ** 2 + imaginary_part ** 2)
argument = math.atan2(imaginary_part, real_part)   # includes the quadrant adjustment (-π < θ ≤ π)
if argument < 0:
    argument += 2 * math.pi                        # move it into the range 0 ≤ θ < 2π
print(f"Absolute value r = {absolute_value}")
print(f"Argument θ = {argument} rad ({math.degrees(argument)} degrees)")

# Polar form -> rectangular form
r = 2
theta_degree = 60
theta = math.radians(theta_degree)
print(f"Real part a = {r * math.cos(theta)}")
print(f"Imaginary part b = {r * math.sin(theta)}")
How to write it in LaTeX and other math languages (copy and paste)
z = r(cosθ + i sinθ)
z = r(\cos\theta + i\sin\theta)
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
<mrow>
<mi>z</mi>
<mo>=</mo>
<mi>r</mi>
<mo>(</mo>
<mi>cos</mi><mi>θ</mi>
<mo>+</mo>
<mi>i</mi><mi>sin</mi><mi>θ</mi>
<mo>)</mo>
</mrow>
</math>
z = r(cos theta + i sin theta)
z == r (Cos[theta] + I Sin[theta])
z := r*(cos(theta) + I*sin(theta));
z = r*(cos(theta) + 1i*sin(theta));
z = r(cos θ + i sin θ)
r = |z| = √(a² + b²)
r = |z| = \sqrt{a^{2} + b^{2}}
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
  <mrow>
    <mi>r</mi>
    <mo>=</mo>
    <mo>|</mo><mi>z</mi><mo>|</mo>
    <mo>=</mo>
    <msqrt>
      <mrow>
        <msup><mi>a</mi><mn>2</mn></msup>
        <mo>+</mo>
        <msup><mi>b</mi><mn>2</mn></msup>
      </mrow>
    </msqrt>
  </mrow>
</math>
r = |z| = sqrt(a^2 + b^2)
Abs[a + b I]
r := abs(a + b*I);
r = abs(a + b*1i);
r = √(a^2 + b^2)
tanθ = b/a
\tan\theta = \dfrac{b}{a}
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
<mrow>
<mi>tan</mi><mi>θ</mi>
<mo>=</mo>
<mfrac><mi>b</mi><mi>a</mi></mfrac>
</mrow>
</math>
tan theta = b/a
theta = Arg[a + b I]
theta := argument(a + b*I);
theta = angle(a + b*1i);
tan θ = b/a
z₁z₂ = r₁r₂{cos(θ₁+θ₂) + i sin(θ₁+θ₂)}
z_{1}z_{2} = r_{1}r_{2}\{\cos(\theta_{1}+\theta_{2}) + i\sin(\theta_{1}+\theta_{2})\}
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
<mrow>
<msub><mi>z</mi><mn>1</mn></msub>
<msub><mi>z</mi><mn>2</mn></msub>
<mo>=</mo>
<msub><mi>r</mi><mn>1</mn></msub>
<msub><mi>r</mi><mn>2</mn></msub>
<mo>{</mo>
<mi>cos</mi>
<mo>(</mo>
<msub><mi>θ</mi><mn>1</mn></msub>
<mo>+</mo>
<msub><mi>θ</mi><mn>2</mn></msub>
<mo>)</mo>
<mo>+</mo>
<mi>i</mi>
<mi>sin</mi>
<mo>(</mo>
<msub><mi>θ</mi><mn>1</mn></msub>
<mo>+</mo>
<msub><mi>θ</mi><mn>2</mn></msub>
<mo>)</mo>
<mo>}</mo>
</mrow>
</math>
z_1 z_2 = r_1 r_2 (cos(theta_1 + theta_2) + i sin(theta_1 + theta_2))
r1 r2 (Cos[theta1 + theta2] + I Sin[theta1 + theta2])
z1z2 := r1*r2*(cos(theta1 + theta2) + I*sin(theta1 + theta2));
z12 = r1*r2*(cos(t1 + t2) + 1i*sin(t1 + t2));
z_1 z_2 = r_1 r_2 (cos(θ_1+θ_2) + i sin(θ_1+θ_2))
How to have ChatGPT do the calculation
You are a math calculation assistant for the complex plane. Do the following calculation by actually running Python code, and base your answer only on the numbers from the execution result (do not answer by mental math or guessing).

1. Convert the complex number z = 3 + 4i to polar form r(cos θ + i sin θ). Show the absolute value r and the argument θ (in the range 0 ≤ θ < 2π, in both radians and degrees).
2. Convert the complex number with absolute value r = 2 and argument θ = 60° to rectangular form a + bi. Show a and b as decimals, and also as exact values with square roots if possible.

In Python, use math.atan2 and math.sqrt, and show the formulas you used and the numbers from the execution result.
How to Use
-
1Enter your numbersType the numbers you want to calculate with into the input fields
-
2CalculatePress the "Calculate" button
-
3Check the resultThe result appears on the spot. The same page also explains the idea behind the calculation and the formula
DataChef Features

No technical knowledge required.
Intuitive and user-friendly operation.
Can be used without registering personal information.
Automatic file deletion by clicking "download".
and rapid file conversion.
No attribution required.
No need to contact us for commercial use permission.
Related Features
Complex Number Calculator (Add, Subtract, Multiply and Divide with Steps, Conjugate, Modulus and Complex Plane)
Adds, subtracts, multiplies and divides two complex numbers z₁ and z₂, with the steps of multiplying by the conjugate, the complex conjugate, the absolute value and a complex plane graph
Sin Cos Tan Calculator (Trig Ratios and Angles with a Unit Circle)
Finds sin, cos and tan from an angle, or an angle from a value, with a unit circle diagram
Degrees to Radians Converter (Exact Answers in Terms of π, with a Unit Circle)
Converts between degrees and radians, with exact values as fractions of π and a unit circle diagram
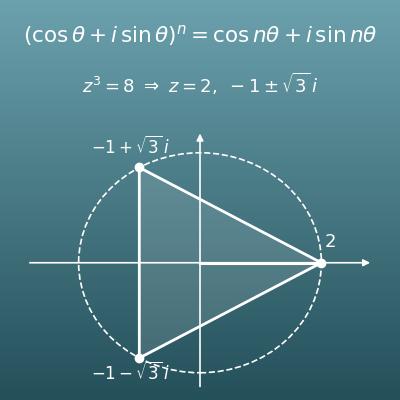
De Moivre's Theorem Calculator (Powers and nth Roots of Complex Numbers with Steps and a Polygon Graph)
Finds powers and nth roots of a complex number with De Moivre's theorem. Steps show the modulus raised to the power and the argument multiplied by n, and the roots are drawn as a regular polygon on a circle
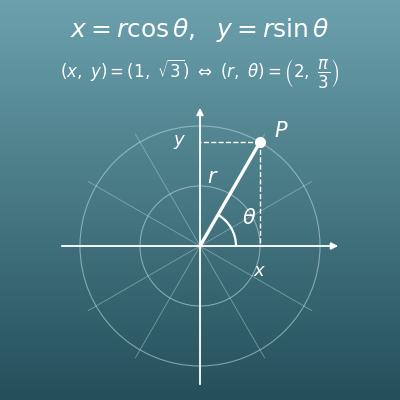
Polar and Rectangular Coordinates Converter (r and θ, Quadrant Steps and a Graph)
Uses the same "distance and direction" idea for the coordinates of a point on the plane. Converts between rectangular coordinates (x, y) and polar coordinates (r, θ)