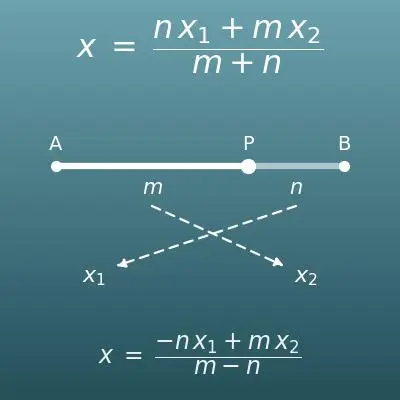
Bookmarks    
nPr and nCr    
Random Number    
SD Calculator    
Sample Size    
Percent Error    
Density    
Molarity    
Molar Mass    
Ohm's Law    
Watts to Amps    
Voltage Drop    
Long Division    
Mixed Numbers    
Rounding    
Nth Root    
Exponents    
Half-Life    
Polar Form    
De Moivre    
3D Distance    
Point to Line    
Cross Product    
Determinant    
Sin Cos Tan    
Triangle Area    
Scale Factor    
Sector Area    
Ellipse Area    
Cube Volume    
Box Volume    
Sphere Volume    
Cone Volume    
Pipe Volume    
Time Duration    
Time Card    
Present Value    
Future Value    
Churn Rate    
A/B Test Calc    
SEO Traffic    
Ideal Weight    
Fat Intake    
Child Height    
Golf Handicap    
Heat Index    
Wind Chill    
Dew Point    
Download Time    
kWh to Cost    
AC Size (BTU)    
Heating Costs    
LED Savings    
Trip Gas Cost    
Tire Size    
Solar Output    
Solar Payback    
Battery Size    
Wall Area    
Gravel Needed    
Mortar Mix    
Slope Grade    
Curtain Size    
Soil Needed    
Sod Needed    
Ramp Length    
Blind Size    
Drain Slope    
Board Feet    
Heat Loss    
Furniture Fit    
Moving Boxes    
Plywood Cuts    
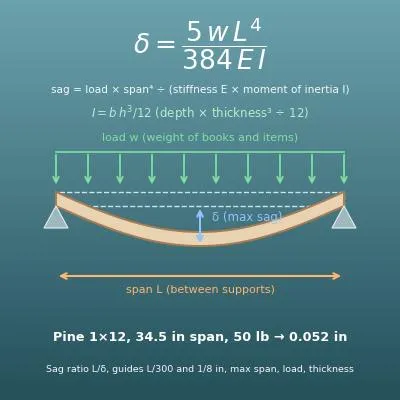
Shelf Sag    
   Add
Probability and random number calculators
Independent Events
Independent Events
Two Events Solver
Two Events Solver
Repeated Trials
Repeated Trials
Bayes' Theorem
Bayes' Theorem
Expected Value
Expected Value
Binomial Distribution
nPr and nCr
nPr and nCr
Circular Permutation
With Repetition
With Repetition
Random Number
Random Number
Averages and statistics calculators
Average Calculator
Average Calculator
Mean Median Mode
Mean Median Mode
SD Calculator
SD Calculator
Quartiles & IQR
Quartiles & IQR
Frequency Table
Frequency Table
Correlation (r)
Correlation (r)
Normal Probability
Normal Probability
Z-Score Calculator
Z-Score Calculator
Confidence Interval
Confidence Interval
Sample Size
Sample Size
Mark & Recapture
Mark & Recapture
P-Value Calculator
P-Value Calculator
Percentage and ratio calculators
Percentage Calc
Percentage Calc
Percent Change
Percent Change
Percent Difference
Percent Difference
Percent Error
Percent Error
Ratio Calculator
Ratio Calculator
Discount Calculator
Discount Calculator
Sales Tax Calculator
Margin Calculator
Margin Calculator
Speed calculators
Speed Calculator
Speed Calculator
Density and concentration calculators
Density
Density
Molarity
Molarity
Molar Mass
Molar Mass
Physics and electricity calculators
Ohm's Law
Ohm's Law
Watts to Amps
Watts to Amps
Resistor Colors
Resistor Colors
Voltage Drop
Voltage Drop
Unit conversion calculators
Weight Converter
Weight Converter
Shoe Size Converter
Shoe Size Converter
Integer and signed number calculators
Long Division
Long Division
LCM Calculator
LCM Calculator
GCF Calculator
GCF Calculator
Integer Calculator
Integer Calculator
Prime Factorization
Prime Factorization
Diophantine Solver
Diophantine Solver
Modulo Calculator
Modulo Calculator
Factor Calculator
Factor Calculator
Roman Numerals
Roman Numerals
Fraction, decimal and rounding calculators
Fraction Calculator
Fraction Calculator
Mixed Numbers
Mixed Numbers
Simplify Fractions
Simplify Fractions
Fraction to Decimal
Fraction to Decimal
Decimal to Fraction
Decimal to Fraction
Rounding
Rounding
Equation and inequality calculators
Linear Equation
Linear Equation
Linear Systems
Linear Systems
Quadratic Formula
Quadratic Formula
Absolute Value
Absolute Value
Quadratic Inequality
Polynomial calculators
Binomial Theorem
Binomial Theorem
Square root and nth root calculators
Simplify Radicals
Simplify Radicals
Nth Root
Nth Root
Exponent and logarithm calculators
Exponents
Exponents
Log Calculator
Log Calculator
Number of Digits
Number of Digits
Scientific Notation
Scientific Notation
Sci. Notation Math
Sci. Notation Math
Half-Life
Half-Life
Complex number calculators
Complex Numbers
Complex Numbers
Polar Form
Polar Form
De Moivre
De Moivre
Function and graph calculators
Slope Calculator
Slope Calculator
Linear Function
Linear Function
Direct & Inverse Variation
y = ax² Calculator
y = ax² Calculator
Distance Formula
Distance Formula
3D Distance
3D Distance
Section Formula
Section Formula
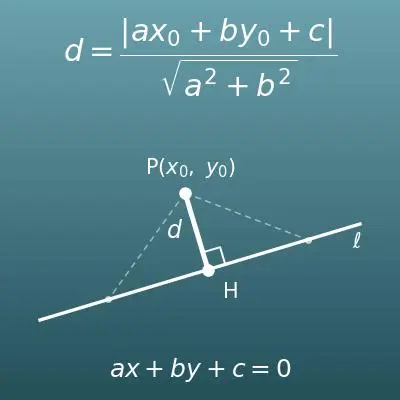
Point to Line
Point to Line
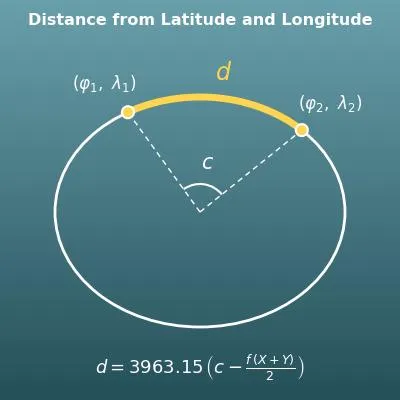
Lat/Long Distance
Lat/Long Distance
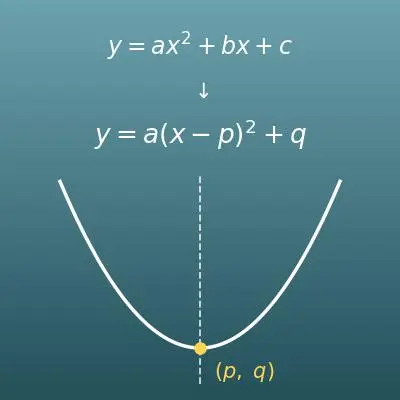
Complete the Square
Complete the Square
Circle Equation
Circle Equation
Conic Sections
Conic Sections
Polar Coordinates
Polar Coordinates
Sequence calculators
Arithmetic Sequence
Arithmetic Sequence
Geometric Sequence
Geometric Sequence
Fibonacci Sequence
Fibonacci Sequence
Recurrence Relation
Recurrence Relation
Vector calculators
Vector Calculator
Vector Calculator
Cross Product
Cross Product
Matrix calculators
Matrix Calculator
Matrix Calculator
Determinant
Determinant
Inverse Matrix
Inverse Matrix
Plane geometry calculators
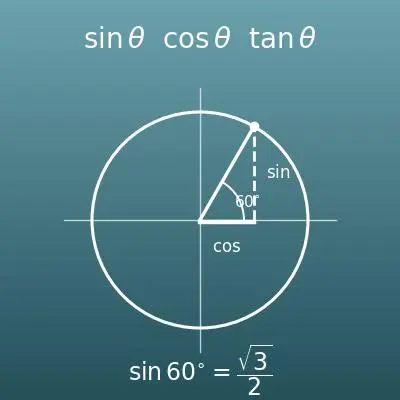
Sin Cos Tan
Sin Cos Tan
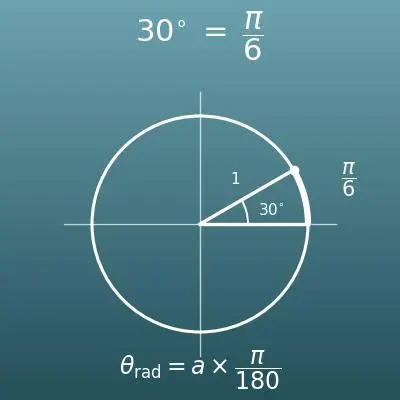
Degrees ⇔ Radians
Degrees ⇔ Radians
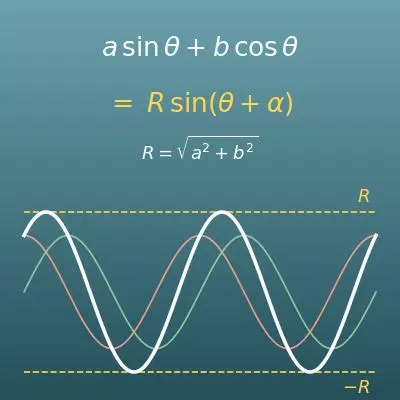
a sin θ + b cos θ
a sin θ + b cos θ
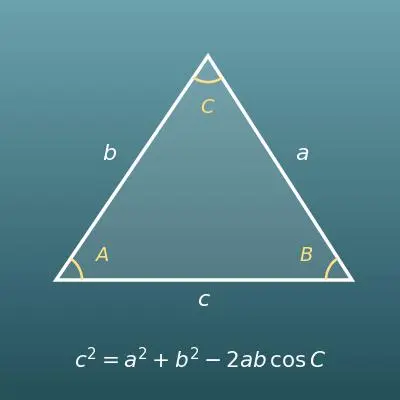
Triangle Solver
Triangle Solver
Triangle Area
Triangle Area
Right Triangle
Right Triangle
Pythagorean Theorem
Pythagorean Theorem
Polygon Angles
Polygon Angles
Scale Factor
Scale Factor
Parallel Lines
Parallel Lines
Rectangle Area
Rectangle Area
Parallelogram Area
Parallelogram Area
Trapezoid Area
Trapezoid Area
Circle Calculator
Circle Calculator
Sector Area
Sector Area
Inscribed Angle
Inscribed Angle
Ellipse Area
Ellipse Area
Solid geometry calculators
Cube Volume
Cube Volume
Cube Surface Area
Cube Surface Area
Box Volume
Box Volume
Box Surface Area
Box Surface Area
Cylinder Volume
Cylinder Volume
Cylinder Surface
Cylinder Surface
Sphere Volume
Sphere Volume
Sphere Surface
Sphere Surface
Spherical Cap Volume
Cap Surface Area
Cap Surface Area
Ellipsoid Volume
Ellipsoid Volume
Ellipsoid Surface
Ellipsoid Surface
Pyramid Volume
Pyramid Volume
Pyramid Surface
Pyramid Surface
Cone Volume
Cone Volume
Cone Surface Area
Cone Surface Area
Frustum Volume
Frustum Volume
Frustum Surface Area
Pipe Volume
Pipe Volume
Capsule Volume
Capsule Volume
Capsule Surface Area
Date and time calculators
Age Calculator
Age Calculator
Days Between Dates
Days Between Dates
Date Calculator
Date Calculator
Hours From Now
Hours From Now
Day of the Week
Day of the Week
Time Calculator
Time Calculator
Time Zone Converter
Time Zone Converter
Hours Calculator
Hours Calculator
Time Duration
Time Duration
Time Card
Time Card
Finance and economics calculators
Compound Interest
Compound Interest
Simple Interest
Simple Interest
Interest Calculator
Interest Calculator
TVM Calculator
TVM Calculator
Present Value
Present Value
Future Value
Future Value
ROI Calculator
ROI Calculator
IRR Calculator
IRR Calculator
Payback Period
Payback Period
Average Return
Average Return
GDP Calculator
GDP Calculator
Web marketing and ad metric calculators
CTR Calculator
CTR Calculator
Conversion Rate
Conversion Rate
CPC, CPM & CPA
CPC, CPM & CPA
ROAS Calculator
ROAS Calculator
Break-Even CPA
Break-Even CPA
LTV Calculator
LTV Calculator
CAC Calculator
CAC Calculator
Churn Rate
Churn Rate
A/B Test Calc
A/B Test Calc
A/B Sample Size
A/B Sample Size
SEO Traffic
SEO Traffic
Break-Even Point
Break-Even Point
Markup vs. Margin
Markup vs. Margin
CAGR Calculator
CAGR Calculator
Health and fitness calculators
BMI Calculator
BMI Calculator
Sleep Calculator
Sleep Calculator
Calorie Calculator
Calorie Calculator
BMR Calculator
BMR Calculator
TDEE Calculator
TDEE Calculator
Ideal Weight
Ideal Weight
Body Fat Calculator
Body Fat Calculator
Lean Body Mass
Lean Body Mass
Calories Burned
Calories Burned
Protein Intake
Protein Intake
Macro Calculator
Macro Calculator
Carb Calculator
Carb Calculator
Fat Intake
Fat Intake
Child Height
Child Height
Sports calculators
Golf Handicap
Golf Handicap
Pace Calculator
Pace Calculator
1RM Calculator
1RM Calculator
Target Heart Rate
Target Heart Rate
Weather calculators
Heat Index
Heat Index
Wind Chill
Wind Chill
Dew Point
Dew Point
Computer calculators
Base Converter
Base Converter
Subnet Calculator
Subnet Calculator
Download Time
Download Time
Household energy and budget calculators
Electricity Cost
Electricity Cost
kWh to Cost
kWh to Cost
Yearly kWh to Cost
Yearly kWh to Cost
AC Size (BTU)
AC Size (BTU)
AC Running Cost
AC Running Cost
Heating Costs
Heating Costs
Gas vs Electric
Gas vs Electric
LED Savings
LED Savings
Salary Calculator
Salary Calculator
Budget Calculator
Budget Calculator
Car calculators
Trip Gas Cost
Trip Gas Cost
EV Charging Cost
EV Charging Cost
EV vs Gas Cost
EV vs Gas Cost
MPG Calculator
MPG Calculator
Tire Size
Tire Size
Solar power and battery calculators
Solar Output
Solar Output
Solar Panel Count
Solar Panel Count
Solar Payback
Solar Payback
Battery Size
Battery Size
Home and DIY calculators
Tile Calculator
Tile Calculator
Stair Calculator
Stair Calculator
Concrete Volume
Concrete Volume
Wall Area
Wall Area
Wallpaper Rolls
Wallpaper Rolls
Paint Calculator
Paint Calculator
Flooring Needed
Flooring Needed
Exterior Walls
Exterior Walls
Gravel Needed
Gravel Needed
Mortar Mix
Mortar Mix
Slope Grade
Slope Grade
Lumber Cut List
Lumber Cut List
Lot Coverage/FAR
Lot Coverage/FAR
Sheet Vinyl Roll
Sheet Vinyl Roll
Insulation Needed
Insulation Needed
Curtain Size
Curtain Size
TV Size & Distance
TV Size & Distance
Soil Needed
Soil Needed
Sod Needed
Sod Needed
Block Calculator
Block Calculator
Brick Calculator
Brick Calculator
Deck Materials
Deck Materials
Ramp Length
Ramp Length
Pilot Hole Size
Pilot Hole Size
Room Ventilation
Room Ventilation
Paint Thinning
Paint Thinning
Baseboard & Trim
Baseboard & Trim
Blind Size
Blind Size
Picture Hanging
Picture Hanging
Drain Slope
Drain Slope
Screw Calculator
Screw Calculator
Board Feet
Board Feet
Fence Calculator
Fence Calculator
Wood Shrinkage
Wood Shrinkage
Caulk Calculator
Caulk Calculator
Heat Loss
Heat Loss
Furniture Fit
Furniture Fit
Moving Boxes
Moving Boxes
Storage Capacity
Storage Capacity
Plywood Cuts
Plywood Cuts
Shelf Sag
Shelf Sag

Polar and Rectangular Coordinates Converter (r and θ, Quadrant Steps and a Graph)

Choose the direction of the conversion and enter the numbers. For "rectangular → polar", enter the x- and y-coordinates. For "polar → rectangular", enter the radius r and the angle θ (and choose its unit).

Enter numbers only. Decimals, negative numbers and fractions such as 3/4 are OK. A blank x or y counts as 0.
Result and figure
Enter the numbers in the fields on the left and press "Calculate". The result and a figure of the coordinate plane will appear here.

What you can do on this page

  • Convert rectangular coordinates \(P(x,\ y)\) to polar coordinates \(P(r,\ \theta)\) on the spot. The radius is given as an exact value with a simplified root, such as \(\sqrt{8} = 2\sqrt{2}\), and for special angles the angle is given exactly as a fraction of π
  • The angle \(\theta\) is given mainly in the range \(0 \le \theta < 2\pi\), with the value for \(-\pi < \theta \le \pi\) shown too, so you can check your answer whichever range your textbook uses
  • You can also convert the other way (polar → rectangular). Enter the radius \(r\) and the angle \(\theta\) (in degrees, as a fraction of π, or in radians as a decimal), and you get \(x = r\cos\theta\) and \(y = r\sin\theta\) as exact values such as \(\left(-2,\ 2\sqrt{3}\right)\)
  • The steps show, one at a time, how the angle is decided from \(\tan\theta = \dfrac{y}{x}\) and the quadrant the point is in (the quadrant adjustment)
  • You can check the result on a figure of the coordinate plane. Light concentric circles (a scale for the radius) and rays (a scale for the angle) show at a glance where the radius \(r\) and the angle \(\theta\) are
This page covers polar coordinates in the plane, as taught in Precalculus. For rectangular \(x\) and \(y\), you can enter fractions and decimals (rational numbers), but not irrational numbers such as √3. With such inputs, the angle comes out as an exact fraction of π only when the point is on an axis or at a 45°-family angle. (For 30° and 60° angles, tanθ is irrational, like 1/√3, so they cannot come from rational \(x\) and \(y\).) In the other direction, polar → rectangular, every special angle that is a multiple of 30° or 45° is calculated exactly.

What is this calculation used for?

Air traffic control and ship radar (location by distance and bearing)

Airport radar and ship radar measure "the distance from here" by the time a radio pulse takes to bounce back, and "the bearing" by the direction the antenna is pointing. So what they measure is polar coordinates \(\left(r,\ \theta\right)\) from the start.
But the controller's screen and nautical charts are built on horizontal and vertical coordinates, so inside the equipment the measured distance and bearing are converted to rectangular coordinates with \(x = r\cos\theta\) and \(y = r\sin\theta\). This page's conversion is what connects a device that measures by distance and direction with a screen that draws across and up.

Distance sensors in self-driving cars and robot vacuums

The laser distance sensors (LiDAR) on self-driving cars and robot vacuums spin around and take a huge number of measurements of the form "something reflected the beam this far away in this direction". Each measurement is a pair of direction (angle) and distance, which is polar coordinates.
To build a map from the collected points, every point is converted to rectangular coordinates and then combined. Mapping the surroundings and then planning a route is the basic flow of self-driving, and this coordinate conversion is where it starts.

Weather radar and hurricane tracking maps

Weather radar also spins its antenna while sending out radio waves, and receives the reflections from rain and snow as "bearing and distance". The rain images in TV weather forecasts are this polar data converted to the horizontal and vertical coordinates of a map.
Giving the position of a hurricane as "150 miles south-southeast of Miami" is also the polar way of thinking, and the conversion to rectangular coordinates happens when the point is plotted on a map.

Designing machines and rides that go around in circles

For things that turn around a center, such as the cars on a Ferris wheel, the teeth of a gear or the blades of a fan, design gets simpler if you think "the distance from the center is fixed and only the direction changes". In polar coordinates you just fix the distance \(r\) and change the angle \(\theta\), which makes placing the parts very easy.
But drawings and CNC machine tools take horizontal and vertical coordinates, so at the end every position is converted to rectangular coordinates before it is handed over.

Circular layouts and motion in computer graphics and games

Placing enemies evenly around the hero, firing bullets in all directions, orbiting a camera around a target: these are most natural to think of in terms of "distance from the center" and "angle", and splitting the angle evenly decides the layout.
The screen is drawn in horizontal and vertical coordinates, so every frame the positions are converted with \(x = r\cos\theta\) and \(y = r\sin\theta\). This conversion is why circular motion is easy to program.

Formulas and figures

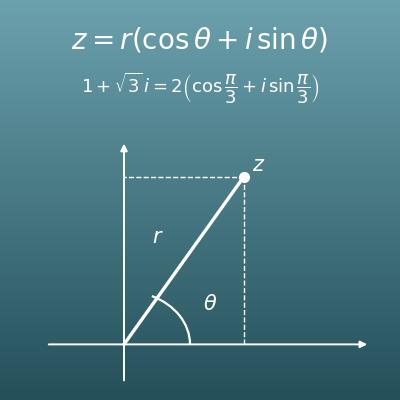
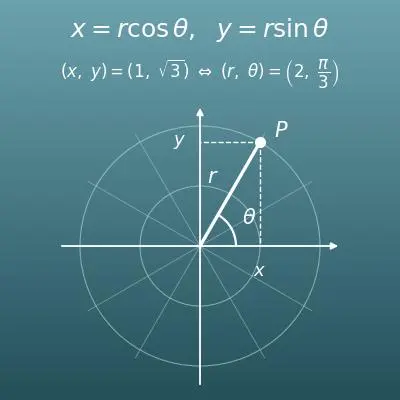
From polar to rectangular (two ways to give the location of a point)
Figure
Standard notation (the usual math form)
\(x\) \(=\) \(r\) \(\cos\theta\)
\(y\) \(=\) \(r\) \(\sin\theta\)
In words (symbols replaced with words)
③ \(x\)-coordinate \(=\) ① \(r\): radius ② cosine of the angle \(\theta\)
④ \(y\)-coordinate \(=\) \(r\): radius sine of the angle \(\theta\)
The formula in words
① Take the distance from the pole (the origin), the radius \(r\)
② multiply it by the cosine of the angle \(\theta\), \(\cos\theta\)
③ and you get the \(x\)-coordinate
④ Multiply the same radius by the sine \(\sin\theta\), and you get the \(y\)-coordinate
Quick example
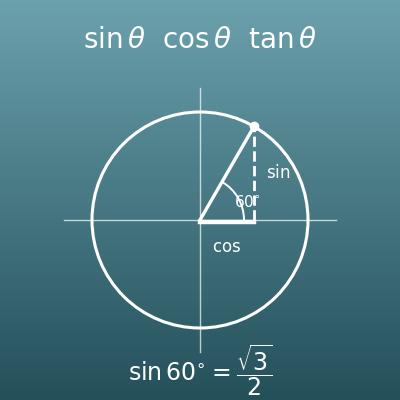
Converting the polar coordinates \(P\left(2,\ \dfrac{\pi}{3}\right)\) (distance 2 from the pole, direction 60° from the polar axis) to rectangular coordinates gives
\(x\)-coordinate \(=\) radius \(2\) \(\cos 60^{\circ} = \dfrac{1}{2}\)
\(y\)-coordinate \(=\) radius \(2\) \(\sin 60^{\circ} = \dfrac{\sqrt{3}}{2}\)
\(x = 2\cos\dfrac{\pi}{3} = 2 \times \dfrac{1}{2} = 1\)
\(y = 2\sin\dfrac{\pi}{3} = 2 \times \dfrac{\sqrt{3}}{2} = \sqrt{3}\)
\(P\left(2,\ \dfrac{\pi}{3}\right) \rightarrow P\left(1,\ \sqrt{3}\right)\)
Key idea
These are two ways to describe the location of the same point. "Go \(x\) to the right and \(y\) up" is rectangular coordinates \((x,\ y)\). "Go the distance \(r\) from a reference point, in the direction turned \(\theta\) from a reference direction" is polar coordinates \((r,\ \theta)\). When meeting a friend, it is the difference between "300 feet east and 400 feet north of the station" and "500 feet from the station, roughly to the northeast". The reference point of polar coordinates is called the pole, and the reference direction (the ray from the pole to the right) is called the polar axis. When you lay polar coordinates over the coordinate plane, the pole goes on the origin and the polar axis on the positive \(x\)-axis. To see why \(x = r\cos\theta\) and \(y = r\sin\theta\), think of the circle of radius 1 (the unit circle). On the unit circle, the point in the direction of the angle \(\theta\) has horizontal position \(\cos\theta\) and vertical position \(\sin\theta\). If the radius is \(r\), the whole picture is scaled up \(r\) times, so both positions are multiplied by \(r\).
Radius \(r\) (distance from the pole)
Standard notation (the usual math form)
In words (symbols replaced with words)
\(r\) \(=\) \(\sqrt{x^{2} + y^{2}}\)
② \(r\): radius \(=\) ① square root of the sum of the squares of \(x\) and \(y\)
The formula in words
① The square root of \(x\) squared plus \(y\) squared, \(\sqrt{x^2 + y^2}\),
② is the radius \(r\)
Quick example
The radius of the point \(P\left(3,\ 4\right)\) is
radius \(r\) \(=\) \(\sqrt{3^2 + 4^2}\)
\(r = \sqrt{3^{2} + 4^{2}} = \sqrt{9 + 16} = \sqrt{25} = 5\)
Key idea
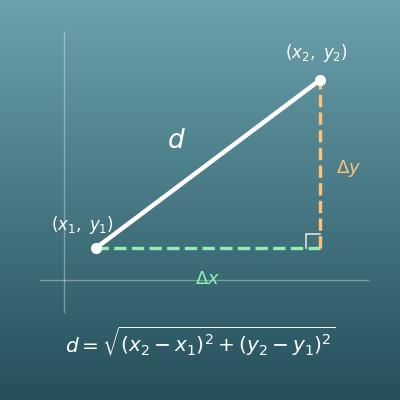
This is exactly the Pythagorean theorem from Grade 8. Join the origin, the point \((x,\ 0)\) and \(P\), and you get a right triangle with legs \(x\) and \(y\). The distance from the origin to \(P\) (the hypotenuse) is \(\sqrt{x^2 + y^2}\). The root in the answer is usually written in simplified form, with square factors taken out, as in \(\sqrt{8} = 2\sqrt{2}\). This calculator also shows the simplified form. In polar coordinates, the radius \(r\) is taken to be 0 or greater. A distance is never negative, so the \(r\) you get from the conversion is never negative.
Angle \(\theta\) (from tanθ and the quadrant)
Standard notation (the usual math form)
In words (symbols replaced with words)
\(\tan\theta\) \(=\) \(\dfrac{y}{x}\)
② tangent of the angle \(\theta\) \(=\) ① \(y\) divided by \(x\)
The formula in words
① The \(y\)-coordinate divided by the \(x\)-coordinate
② is the tangent of the angle \(\theta\), \(\tan\theta\) (this alone does not fix \(\theta\), so you narrow it down by the quadrant that \(P\) is in)
Quick example
The angle of the point \(P\left(-1,\ 1\right)\) (\(x\) is negative and \(y\) is positive, so the point is in Quadrant II) is
tangent \(\tan\theta\) \(=\) \(\dfrac{1}{-1} = -1\)
\(\tan\theta = \dfrac{1}{-1} = -1\)
\(\theta = \dfrac{3}{4}\pi \quad \left(x < 0,\ y > 0\right)\)
Key idea
In the range \(0 \le \theta < 2\pi\), there are two angles with \(\tan\theta = -1\): \(\dfrac{3}{4}\pi\) (135°) and \(\dfrac{7}{4}\pi\) (315°). Which one is right depends on the quadrant of the point \(P\). \(P(-1,\ 1)\) has negative \(x\) and positive \(y\), so it is in Quadrant II (upper left), and we choose \(\theta = \dfrac{3}{4}\pi\). This is the quadrant adjustment. The \(\arctan\) (inverse tangent) on a calculator or in a spreadsheet only returns angles between \(-\dfrac{\pi}{2}\) and \(\dfrac{\pi}{2}\), so for points in Quadrants II and III it does not give the angle directly. You need to adjust the angle from \(\arctan\), for example by adding \(\pi\) depending on the quadrant. (This calculator shows this adjustment in the steps.) For a point with \(x = 0\) (on the \(y\)-axis), \(\dfrac{y}{x}\) cannot be calculated. In that case, decide from the figure that \(\theta = \dfrac{\pi}{2}\) or \(\dfrac{3}{2}\pi\). If you want a method that works for every point, choose the \(\theta\) that satisfies both \(\cos\theta = \dfrac{x}{r}\) and \(\sin\theta = \dfrac{y}{r}\). Then you do not need to split into quadrant cases.
The same point has more than one set of polar coordinates
Standard notation (the usual math form)
\(P\left(r,\ \theta\right)\) \(=\) \(P\left(r,\ \theta + 2n\pi\right)\)
In words (symbols replaced with words)
① point \(P\) at polar coordinates \(\left(r,\ \theta\right)\) \(=\) ② point with \(n\) full turns \(2\pi\) added to the angle
The formula in words
① The point \(P\) at polar coordinates \(\left(r,\ \theta\right)\)
② and the point with \(n\) full turns \(2\pi\) added to the angle are the same point (\(n\) is an integer)
Quick example
Other polar coordinates for the same point as \(P\left(2,\ \dfrac{\pi}{3}\right)\) are
\(P\left(2,\ \dfrac{\pi}{3}\right)\) \(=\) \(P\left(2,\ \dfrac{7}{3}\pi\right)\) \(=\) \(P\left(2,\ -\dfrac{5}{3}\pi\right)\)
\(\dfrac{\pi}{3} + 2\pi = \dfrac{\pi}{3} + \dfrac{6}{3}\pi = \dfrac{7}{3}\pi\)
\(\dfrac{\pi}{3} - 2\pi = \dfrac{\pi}{3} - \dfrac{6}{3}\pi = -\dfrac{5}{3}\pi\)
Key idea
In rectangular coordinates, each point has exactly one pair \((x,\ y)\), but polar coordinates are different. After one full turn (\(2\pi\) = 360°) you face the same direction again, so adding or subtracting \(2\pi\) to the angle any number of times gives the same point. Since the answer is not fixed as it is, you agree on a range when you give an answer. The two common ones are \(0 \le \theta < 2\pi\) (0° or more and less than 360°) and \(-\pi < \theta \le \pi\) (more than −180° and up to 180°), and textbooks differ on which they use. This calculator shows both answers. The pole (the origin) is special. Its distance is 0, so \(r = 0\), but it has no direction, so the angle is not fixed. The polar coordinates of the pole are written \(\left(0,\ \theta\right)\) (\(\theta\) is any value), usually \(\left(0,\ 0\right)\).
A point in the plane can be written in rectangular coordinates \(\left(x,\ y\right)\) (horizontal and vertical position) or in polar coordinates \(\left(r,\ \theta\right)\) (distance from the pole and direction from the polar axis). From polar to rectangular, use \(x = r\cos\theta\) and \(y = r\sin\theta\). The other way, use \(r = \sqrt{x^2 + y^2}\) and \(\tan\theta = \dfrac{y}{x}\), plus the quadrant adjustment that picks the angle by the quadrant of the point. An angle shifted by full turns gives the same point, so answers are given in a fixed range such as \(0 \le \theta < 2\pi\).

Symbols and terms

Symbols

\(P\) pee A letter often used for a point in the plane, from the first letter of "point". The coordinates of the point are written in the parentheses after it, as in \(P\left(1,\ 2\right)\).
\(O\) oh The letter for the origin (the pole), from the first letter of "origin". In polar coordinates, distances are measured from this point.
\(x,\ y\) x, y The horizontal (\(x\)-axis direction) and vertical (\(y\)-axis direction) positions in rectangular coordinates. Both can be negative.
\(r\) are The letter for the radius (the distance from the pole to the point), from the first letter of "radius". In polar coordinates it is a real number 0 or greater.
\(\theta\) theta The Greek letter used for the angle. In math it is the usual letter for an angle.
\(\left(r,\ \theta\right)\) r, theta How polar coordinates are written: first the distance (radius), then the direction (angle). It looks just like rectangular \(\left(x,\ y\right)\), so always say which kind of coordinates you are using.
\(\cos\theta,\ \sin\theta\) cosine theta, sine theta Trigonometric ratios (trigonometric functions). On the circle of radius 1 (the unit circle), the point in the direction of the angle \(\theta\) has horizontal position \(\cos\theta\) and vertical position \(\sin\theta\). They are the key to converting polar to rectangular.
\(\tan\theta\) tangent theta One of the trigonometric ratios, defined as \(\tan\theta = \dfrac{\sin\theta}{\cos\theta}\). On the coordinate plane, \(\tan\theta = \dfrac{y}{x}\) (rise over run, the slope of the line through the origin and the point), which is the clue for finding the angle.
\(\arctan\) arctangent The inverse of the tangent (also written \(\tan^{-1}\)). It returns the angle \(\theta\) with \(\tan\theta = k\). The angles it returns are limited to between \(-\dfrac{\pi}{2}\) and \(\dfrac{\pi}{2}\), so a quadrant adjustment is needed for angles in Quadrants II and III.
\(\pi\) pi The ratio of a circle's circumference to its diameter (about 3.14159). In radian measure, a half turn, \(180^{\circ}\), is exactly \(\pi\). The Greek letter \(\pi\) is said to come from the first letter of the Greek word for "perimeter".
\(n\) en A letter often used for an integer, from the first letter of "number". On this page it is how many full turns the angle is shifted, including negative integers (turning the other way) and 0 (no turn).

Terms

rectangular coordinates A way to give the position of a point as a pair \(\left(x,\ y\right)\): how far across and how far up. These are the everyday coordinates used since middle school, also called Cartesian coordinates.
polar coordinates A way to give the position of a point as a pair \(\left(r,\ \theta\right)\): the distance \(r\) from a reference point and the angle \(\theta\) from a reference direction. They are taught in Precalculus.
pole The reference point from which distances are measured in polar coordinates. On the coordinate plane it is placed at the origin \(O\).
polar axis The reference ray from which angles are measured in polar coordinates. It starts at the pole, and on the coordinate plane it lies along the positive \(x\)-axis.
radius The distance \(r\) from the pole to the point \(P\) (also called the radial coordinate). Strictly, the segment (or ray) joining the pole and \(P\) is also meant, with length \(r\). It is 0 or greater.
angle θ The angle \(\theta\) of the direction from the pole to the point \(P\), measured counterclockwise from the polar axis (also called the polar angle or argument). Adding a full turn (\(2\pi\)) gives the same direction, so answers are usually given in a range such as \(0 \le \theta < 2\pi\) or \(-\pi < \theta \le \pi\).
quadrant One of the four regions the two axes divide the coordinate plane into. The upper right is Quadrant I, and counting counterclockwise from there come Quadrants II, III and IV. Knowing which quadrant a point is in is the clue for fixing the angle.
quadrant adjustment Within one full turn, two angles satisfy \(\tan\theta = \dfrac{y}{x}\), so you choose the one that matches the quadrant of the point (for example, by adding \(\pi\) to the acute angle from \(\arctan\)). This fix is the quadrant adjustment.
unit circle The circle of radius 1 centered at the origin. The point on it in the direction of the angle \(\theta\) is \(\left(\cos\theta,\ \sin\theta\right)\), which is the basis of the polar conversion formulas.
radian measure Measuring an angle by the length of the arc on a circle of radius 1. \(180^{\circ} = \pi\) radians. From trigonometric functions in Algebra 2 and Precalculus on, radians are the standard unit rather than degrees.
special angles \(30^{\circ}\), \(45^{\circ}\), \(60^{\circ}\) and the angles related to them (these plus multiples of \(90^{\circ}\)). Their trigonometric ratios can be written exactly, such as \(\dfrac{1}{2}\), \(\dfrac{\sqrt{2}}{2}\) and \(\dfrac{\sqrt{3}}{2}\), and most textbook and test problems use them.
polar equation An equation of a curve written as a relationship between \(r\) and \(\theta\). For example, \(r = 2\) is the circle of radius 2 centered at the origin, and \(\theta = \dfrac{\pi}{4}\) is the ray from the origin with slope 1. Figures determined by the distance from a center, such as circles and spirals, have much simpler equations than in rectangular coordinates.

Good to know before you start

Here is what helps you use the calculation on this page with real understanding, not just by pressing the button.
If you get stuck, going back to review these topics is the fastest way forward.

The coordinate plane (Grades 5–6)
  • Being able to write the position of a point as a pair \(\left(x,\ y\right)\)
  • Knowing where Quadrants I to IV are and the signs of \(x\) and \(y\) in each
Square roots and radicals (Grade 8 and Algebra 1)
  • Knowing that \(\sqrt{2}\) is the positive number whose square is 2
  • Being able to simplify a root by taking out square factors, as in \(\sqrt{8} = 2\sqrt{2}\)
The Pythagorean theorem (Grade 8)
  • Knowing that the hypotenuse of a right triangle with legs \(a\) and \(b\) is \(\sqrt{a^2 + b^2}\)
  • Knowing that the distance from the origin to a point on the coordinate plane can be found with the Pythagorean theorem
Trigonometric ratios and the unit circle (Geometry, Algebra 2 and Precalculus)
  • Knowing that \(\sin\), \(\cos\) and \(\tan\) are the vertical position, horizontal position and slope of a point on the unit circle
  • Knowing the trigonometric values of \(30^{\circ}\), \(45^{\circ}\) and \(60^{\circ}\) (\(\dfrac{1}{2}\), \(\dfrac{\sqrt{2}}{2}\), \(\dfrac{\sqrt{3}}{2}\))
  • Being able to find trigonometric ratios of angles over \(90^{\circ}\) with the unit circle (for example, \(\cos 135^{\circ} = -\dfrac{\sqrt{2}}{2}\))
Radian measure (Algebra 2 and Precalculus)
  • Being able to convert between degrees and radians with \(180^{\circ} = \pi\) radians (for example, \(60^{\circ} = \dfrac{\pi}{3}\))
Polar coordinates (Precalculus)
  • Knowing what the pole, the polar axis, the radius and the angle refer to
  • Knowing that the same point has more than one set of polar coordinates (shifting the angle by \(2\pi\) gives the same point)

How to calculate it in Excel

Copy the whole table below and paste it into cell A1 in Excel. It works as is.
Table for rectangular → polar
x-coordinate 3
y-coordinate 4
Radius r =SQRT(B1^2+B2^2)
Angle θ (radians, 0 ≤ θ < 2π) =MOD(ATAN2(B1,B2),2*PI())
Angle θ (degrees) =DEGREES(MOD(ATAN2(B1,B2),2*PI()))
Table for polar → rectangular
Radius r 2
Angle θ (degrees) 60
x-coordinate = r cosθ =B1*COS(RADIANS(B2))
y-coordinate = r sinθ =B1*SIN(RADIANS(B2))
Table for another angle for the same point
Angle θ (degrees) 60
Number of turns n (integer, may be negative) 1
Shifted angle (degrees) =B1+360*B2
After pasting, the upper rows are your inputs and the lower rows are calculated automatically.
In the first table, ATAN2(x-coordinate, y-coordinate) returns the angle with the quadrant adjustment already done (more than −π and up to π). Taking MOD with 2π turns it into an angle from 0 up to (but not including) 2π. For the example point (3, 4), r = 5 and θ ≈ 0.9273 (about 53.13 degrees).
In the second table, RADIANS converts degrees to radians. For the example r = 2 and θ = 60 degrees, x = 1 and y ≈ 1.7320508 (= √3). Excel gives decimal answers, so use the calculator on this page when you want exact values such as √3 or fractions of π.
The third table makes other polar coordinates for the same point. Adding one full turn, 360 degrees, to the example 60 degrees gives 420 degrees. With n = −1 you get −300 degrees, and all of these are the same point.

How to calculate it in Google Sheets

Copy the whole table below and paste it into cell A1 in Google Sheets. It works as is.
Table for rectangular → polar
x-coordinate 3
y-coordinate 4
Radius r =SQRT(B1^2+B2^2)
Angle θ (radians, 0 ≤ θ < 2π) =MOD(ATAN2(B1,B2),2*PI())
Angle θ (degrees) =DEGREES(MOD(ATAN2(B1,B2),2*PI()))
Table for polar → rectangular
Radius r 2
Angle θ (degrees) 60
x-coordinate = r cosθ =B1*COS(RADIANS(B2))
y-coordinate = r sinθ =B1*SIN(RADIANS(B2))
Table for another angle for the same point
Angle θ (degrees) 60
Number of turns n (integer, may be negative) 1
Shifted angle (degrees) =B1+360*B2
The same formulas as in Excel work as is (ATAN2 takes its arguments in the same order, "x-coordinate, y-coordinate"). Copy the whole table, paste it into cell A1, and replace the numbers with your own.

How to calculate it in Python

import math

# Rectangular → polar
x_coordinate = 3
y_coordinate = 4
radius = math.sqrt(x_coordinate ** 2 + y_coordinate ** 2)
argument = math.atan2(y_coordinate, x_coordinate)   # includes the quadrant adjustment (−π < θ ≤ π)
if argument < 0:
    argument += 2 * math.pi                         # move into the range 0 ≤ θ < 2π
print(f"Radius r = {radius}")
print(f"Angle θ = {argument} rad ({math.degrees(argument)} degrees)")

# Polar → rectangular
r = 2
theta_degree = 60
theta = math.radians(theta_degree)
print(f"x-coordinate = {r * math.cos(theta)}")
print(f"y-coordinate = {r * math.sin(theta)}")
math.atan2(y, x) returns the angle with the quadrant adjustment already done, so unlike arctan it gives the right direction for points in Quadrants II and III too. Its arguments are in the order "y, x", the opposite of how coordinates are written, which is an easy place to slip. The first half of this example converts the point (3, 4); running it shows r = 5.0 and θ ≈ 0.9272952180016122 rad (about 53.13 degrees). The second half is the reverse conversion with r = 2 and θ = 60°, giving x ≈ 1.0000000000000002 and y ≈ 1.7320508075688772 (= √3). x is not exactly 1 because of rounding error in decimal (floating-point) numbers; to get exact values you need to calculate with symbols, as the calculator on this page does. With the cmath module from the standard library, cmath.polar(complex(3, 4)) also gives the radius and the angle (−π < θ ≤ π) in one step.

How to write it in LaTeX and other math languages (copy and paste)

From polar to rectangular (two ways to give the location of a point)
x = r cosθ, y = r sinθ
x = r\cos\theta,\quad y = r\sin\theta
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
  <mtable columnalign="left">
    <mtr><mtd>
      <mi>x</mi><mo>=</mo><mi>r</mi><mi>cos</mi><mi>&#x3B8;</mi>
    </mtd></mtr>
    <mtr><mtd>
      <mi>y</mi><mo>=</mo><mi>r</mi><mi>sin</mi><mi>&#x3B8;</mi>
    </mtd></mtr>
  </mtable>
</math>
x = r cos theta, y = r sin theta
{x, y} = {r Cos[theta], r Sin[theta]}
x := r*cos(theta); y := r*sin(theta);
[x, y] = pol2cart(theta, r);
x = r cos θ, y = r sin θ
Radius \(r\) (distance from the pole)
r = √(x² + y²)
r = \sqrt{x^{2} + y^{2}}
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
  <mrow>
    <mi>r</mi>
    <mo>=</mo>
    <msqrt>
      <mrow>
        <msup><mi>x</mi><mn>2</mn></msup>
        <mo>+</mo>
        <msup><mi>y</mi><mn>2</mn></msup>
      </mrow>
    </msqrt>
  </mrow>
</math>
r = sqrt(x^2 + y^2)
r = Sqrt[x^2 + y^2]
r := sqrt(x^2 + y^2);
r = hypot(x, y);
r = √(x^2 + y^2)
Angle \(\theta\) (from tanθ and the quadrant)
tanθ = y/x
\tan\theta = \dfrac{y}{x}
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
  <mrow>
    <mi>tan</mi><mi>&#x3B8;</mi>
    <mo>=</mo>
    <mfrac><mi>y</mi><mi>x</mi></mfrac>
  </mrow>
</math>
tan theta = y/x
theta = ArcTan[x, y]
theta := arctan(y, x);
theta = atan2(y, x);
tan θ = y/x
The same point has more than one set of polar coordinates
(r, θ) = (r, θ + 2nπ)
\left(r,\ \theta\right) = \left(r,\ \theta + 2n\pi\right)
<math xmlns="http://www.w3.org/1998/Math/MathML" display="block">
  <mrow>
    <mo>(</mo><mi>r</mi><mo>,</mo><mi>&#x3B8;</mi><mo>)</mo>
    <mo>=</mo>
    <mo>(</mo><mi>r</mi><mo>,</mo>
    <mi>&#x3B8;</mi><mo>+</mo><mn>2</mn><mi>n</mi><mi>&#x3C0;</mi>
    <mo>)</mo>
  </mrow>
</math>
(r, theta) = (r, theta + 2 n pi)
theta + 2 n Pi
theta + 2*n*Pi;
theta2 = theta + 2*n*pi;
(r, θ) = (r, θ + 2nπ)

How to have ChatGPT  do the calculation

You are a math assistant for polar coordinates in the plane. Do the following calculation by actually running Python code, and base your answer only on the numbers from the execution result (do not answer by mental math or guessing).

1. Convert the point (3, 4) in rectangular coordinates to polar coordinates (r, θ). Show the radius r and the angle θ (in the range 0 ≤ θ < 2π, in both radians and degrees).
2. Convert the point (2, 60°) in polar coordinates to rectangular coordinates (x, y). Show x and y as decimals and, if possible, as exact values with √.

In Python, use math.atan2 and math.sqrt, and show the formulas you used and the numbers from the execution result.

How to Use
  1. 1
    Enter your numbers
    Type the numbers you want to calculate with into the input fields
  2. 2
    Calculate
    Press the "Calculate" button
  3. 3
    Check the result
    The result appears on the spot. The same page also explains the idea behind the calculation and the formula
  DataChef Features
Easy and Free
Unlimited conversions for free.
No technical knowledge required.
Intuitive and user-friendly operation.
No Registration Required
Available immediately after access.
Can be used without registering personal information.
Safe and Secure
Fully SSL encrypted communication.
Automatic file deletion by clicking "download".
Fast
High-speed site access
and rapid file conversion.
No Watermark
No watermark.
No attribution required.
Commercial Use Available
Free for commercial use.
No need to contact us for commercial use permission.